Situated Virtual Reality for Telerobotic Control
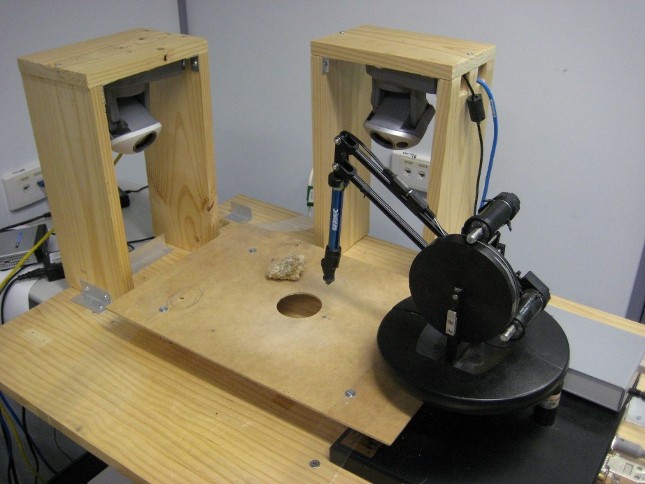
Stéphane Bersot has developed a Situated Virtual Reality for Telerobotic Control system which allows an operator to control a piece of machinery in a remote location by viewing a 3D representation of the remote scene. The cool thing about this is since you are looking at a representation of the remote location you are able to see everything at any angle you want including positions that the physical remote cameras




